01
Sense
NARI gathers plant, soil, environmental and robot observations through vision, LiDAR, AIoT sensors and edge intelligence.
View Evidence
Public summaries only
Nature-aware agricultural intelligence
MahaaAi is building a closed-loop agricultural platform that brings together plant intelligence, digital twins, multi-arm robotics, water intelligence and governed autonomy.
NARI Intelligence Lifecycle
Sense → Understand → Twin → Reason → Govern → Act → Learn. NARI connects plant intelligence, Digital Twins, Somavati governance, multi-arm robotics and evidence-based learning as one Physical AI system. Adaptation stays inside governed validation and human oversight.
Select a stage to see how intelligence becomes a governed, verifiable action.
Space plays or pauses. Arrow keys change stage. Keys 1 to 7 jump. R replays.
Stage 01 of 07: Sense
 CHANDI-18
Physical validation pending
Loop progress 0 percent01
NARI gathers plant, soil, environmental and robot observations through vision, LiDAR, AIoT sensors and edge intelligence.
Public summaries only
Play the full cycle or select a stage to explore.
01 / 07 Sense
Interactive system visualization — synthetic telemetry and simulated robot actions. Physical validation pending.Protected Innovation · Patent Pending
Responsible Intelligence
MahaaAi is building AI and Physical AI systems in which responsibility, context, safety and human values are architectural concerns — not afterthoughts.
For MahaaAi, ethics is not a paragraph added after a model is built. It informs how systems perceive, reason, recommend, collaborate and ultimately act in the physical world.
Understand context before acting.
Evaluate evidence, uncertainty and consequences.
Apply safety boundaries and human oversight.
Translate intelligence into accountable action.
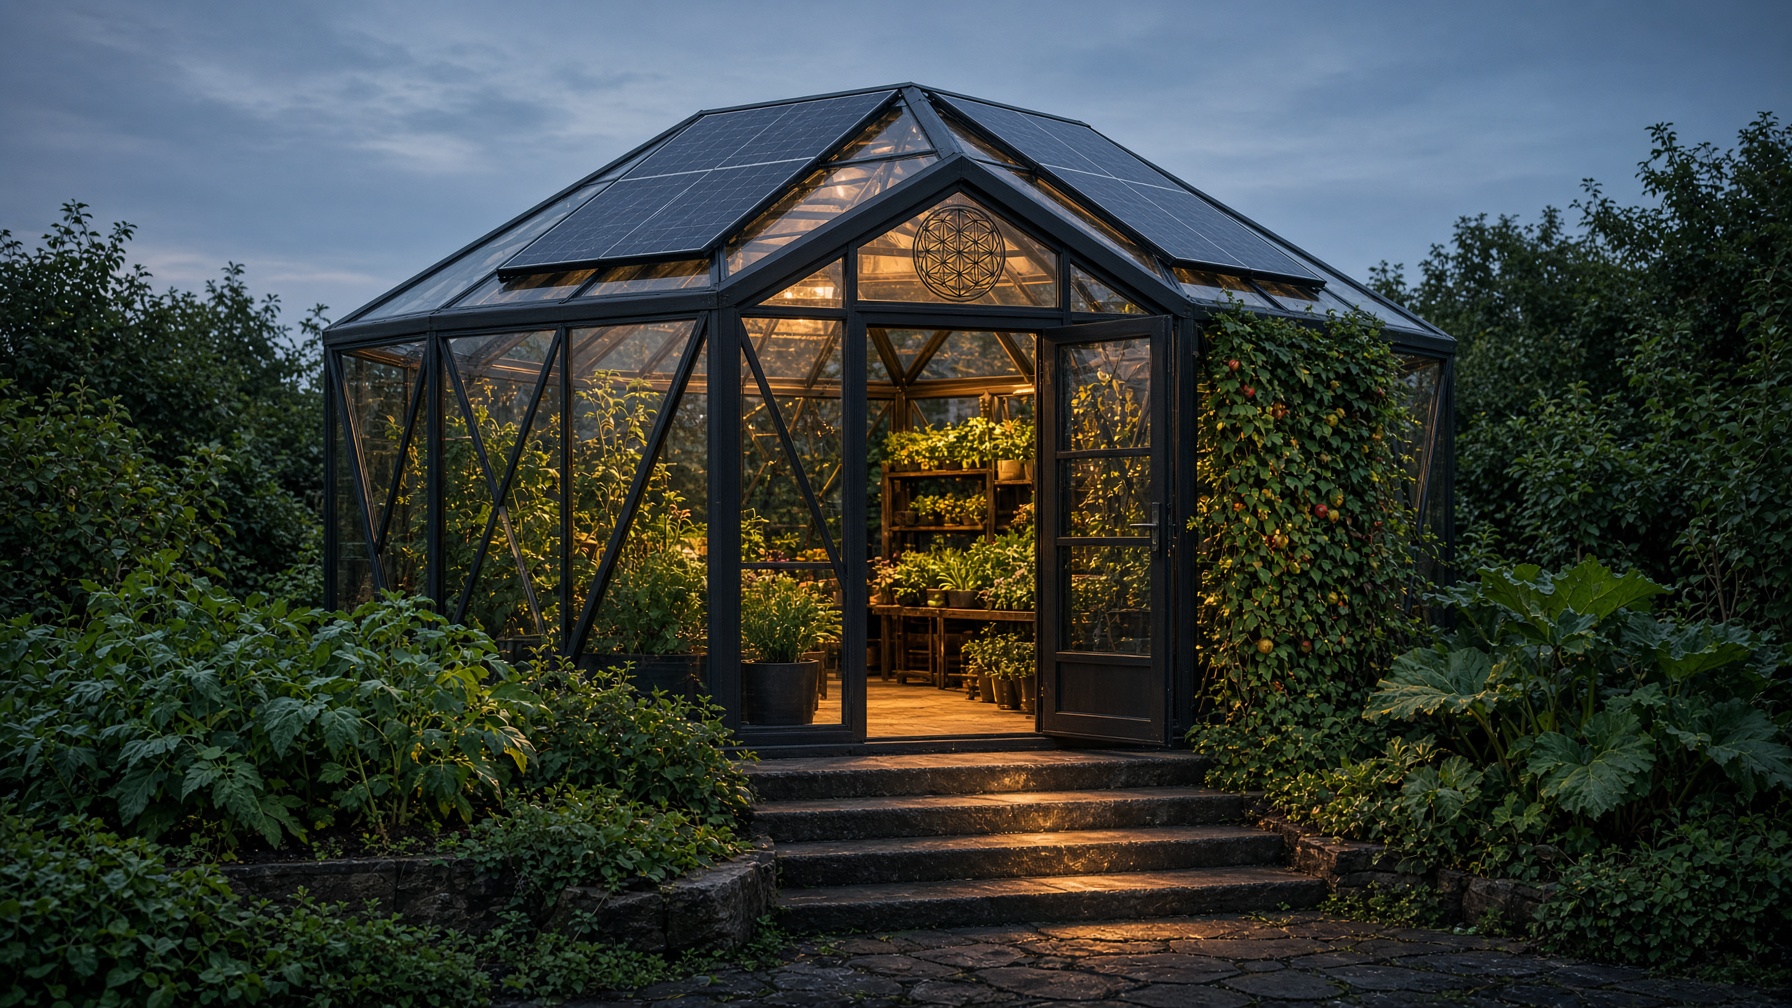
MahaaAi living systems
A planned physical integration environment for plant intelligence, robotics, water, energy, sensing and Digital Twin validation.
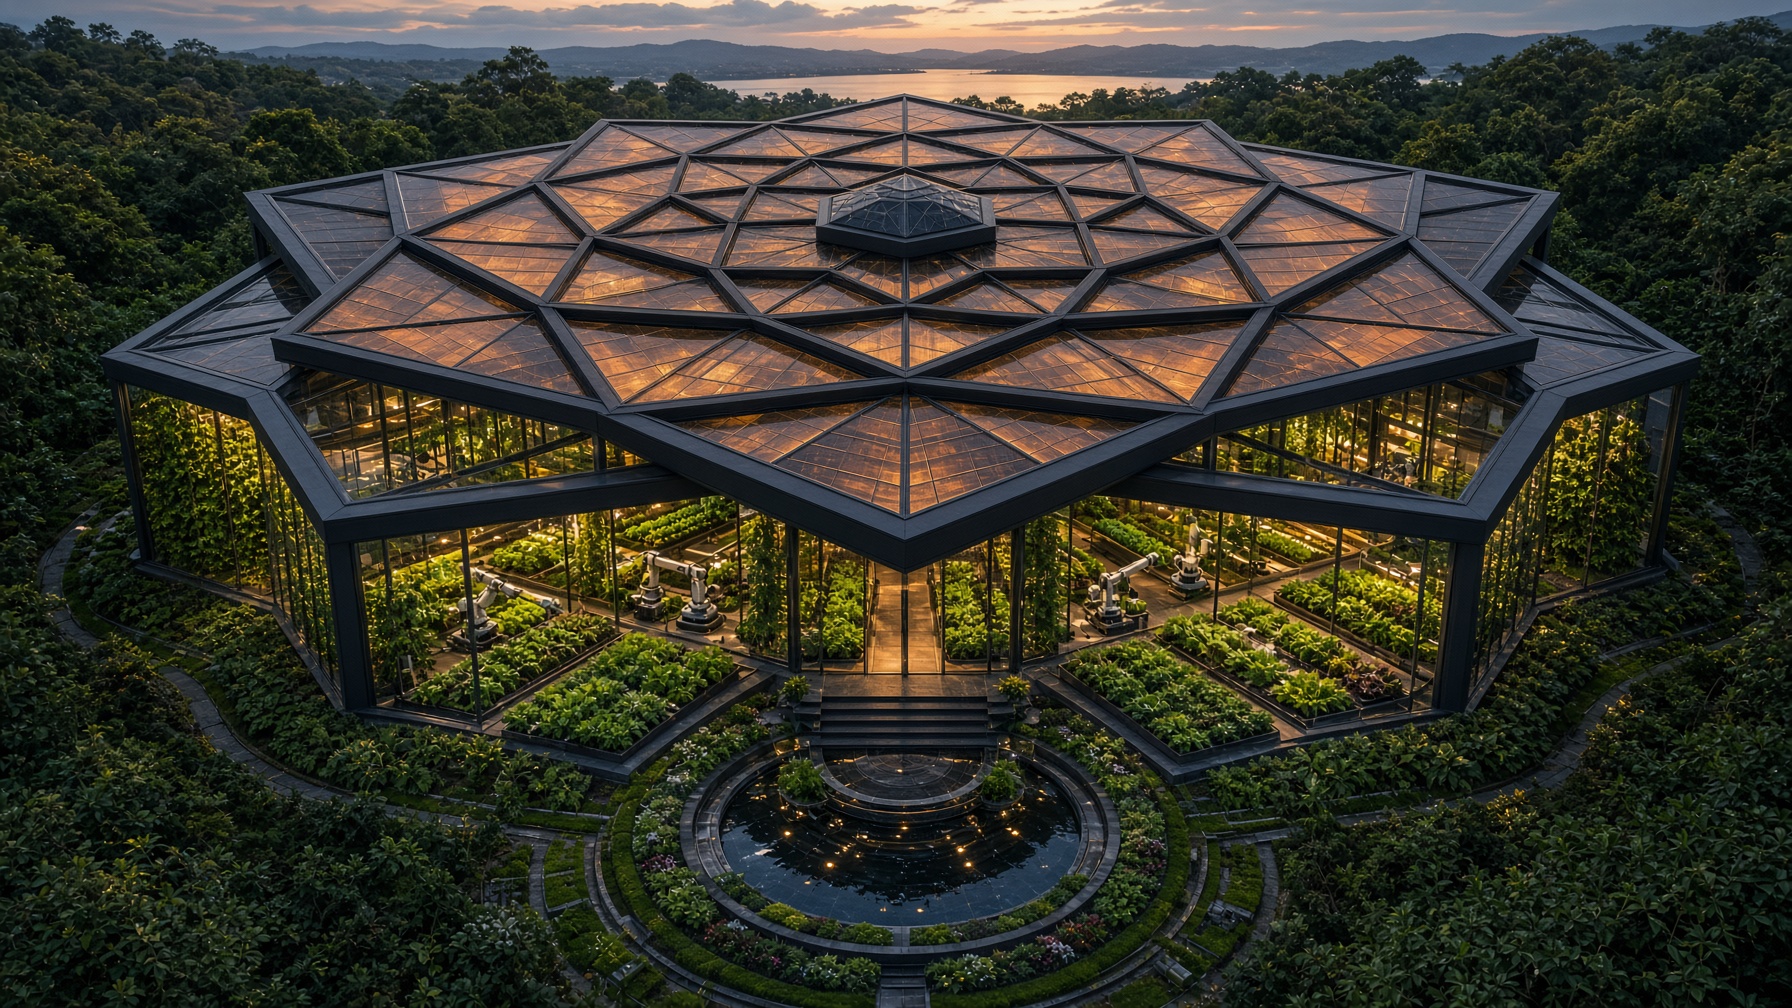 Concept rendering
Physical AI
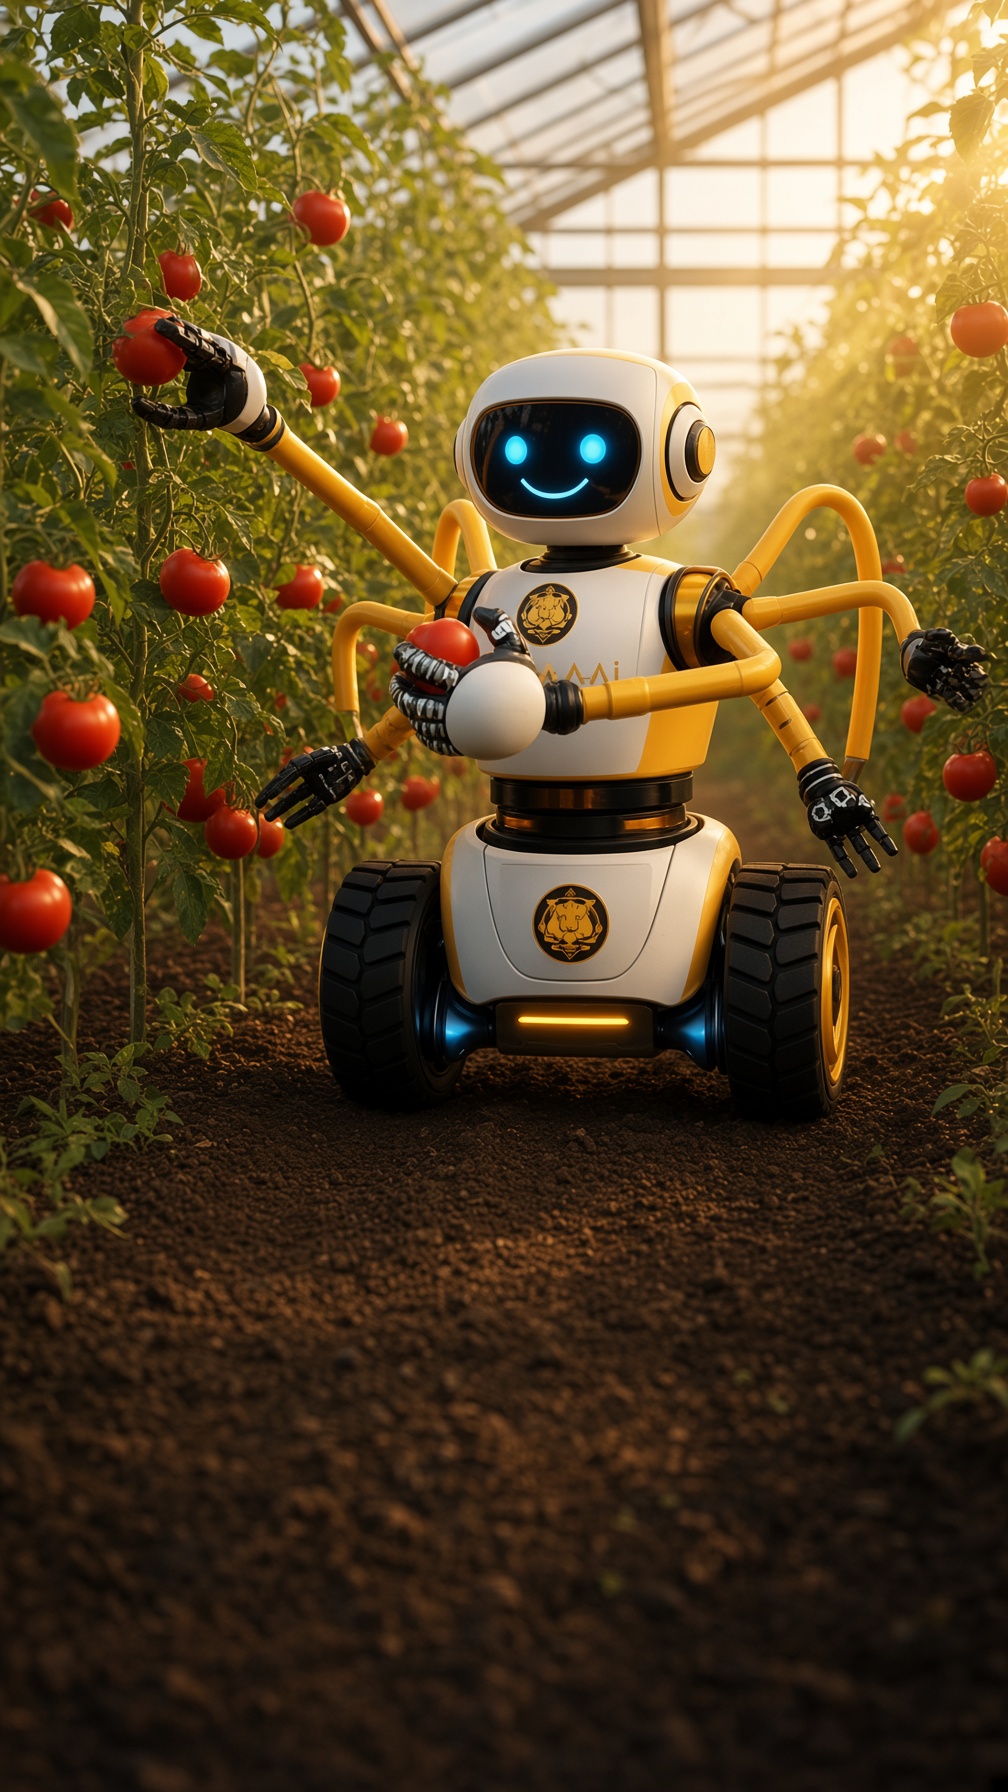
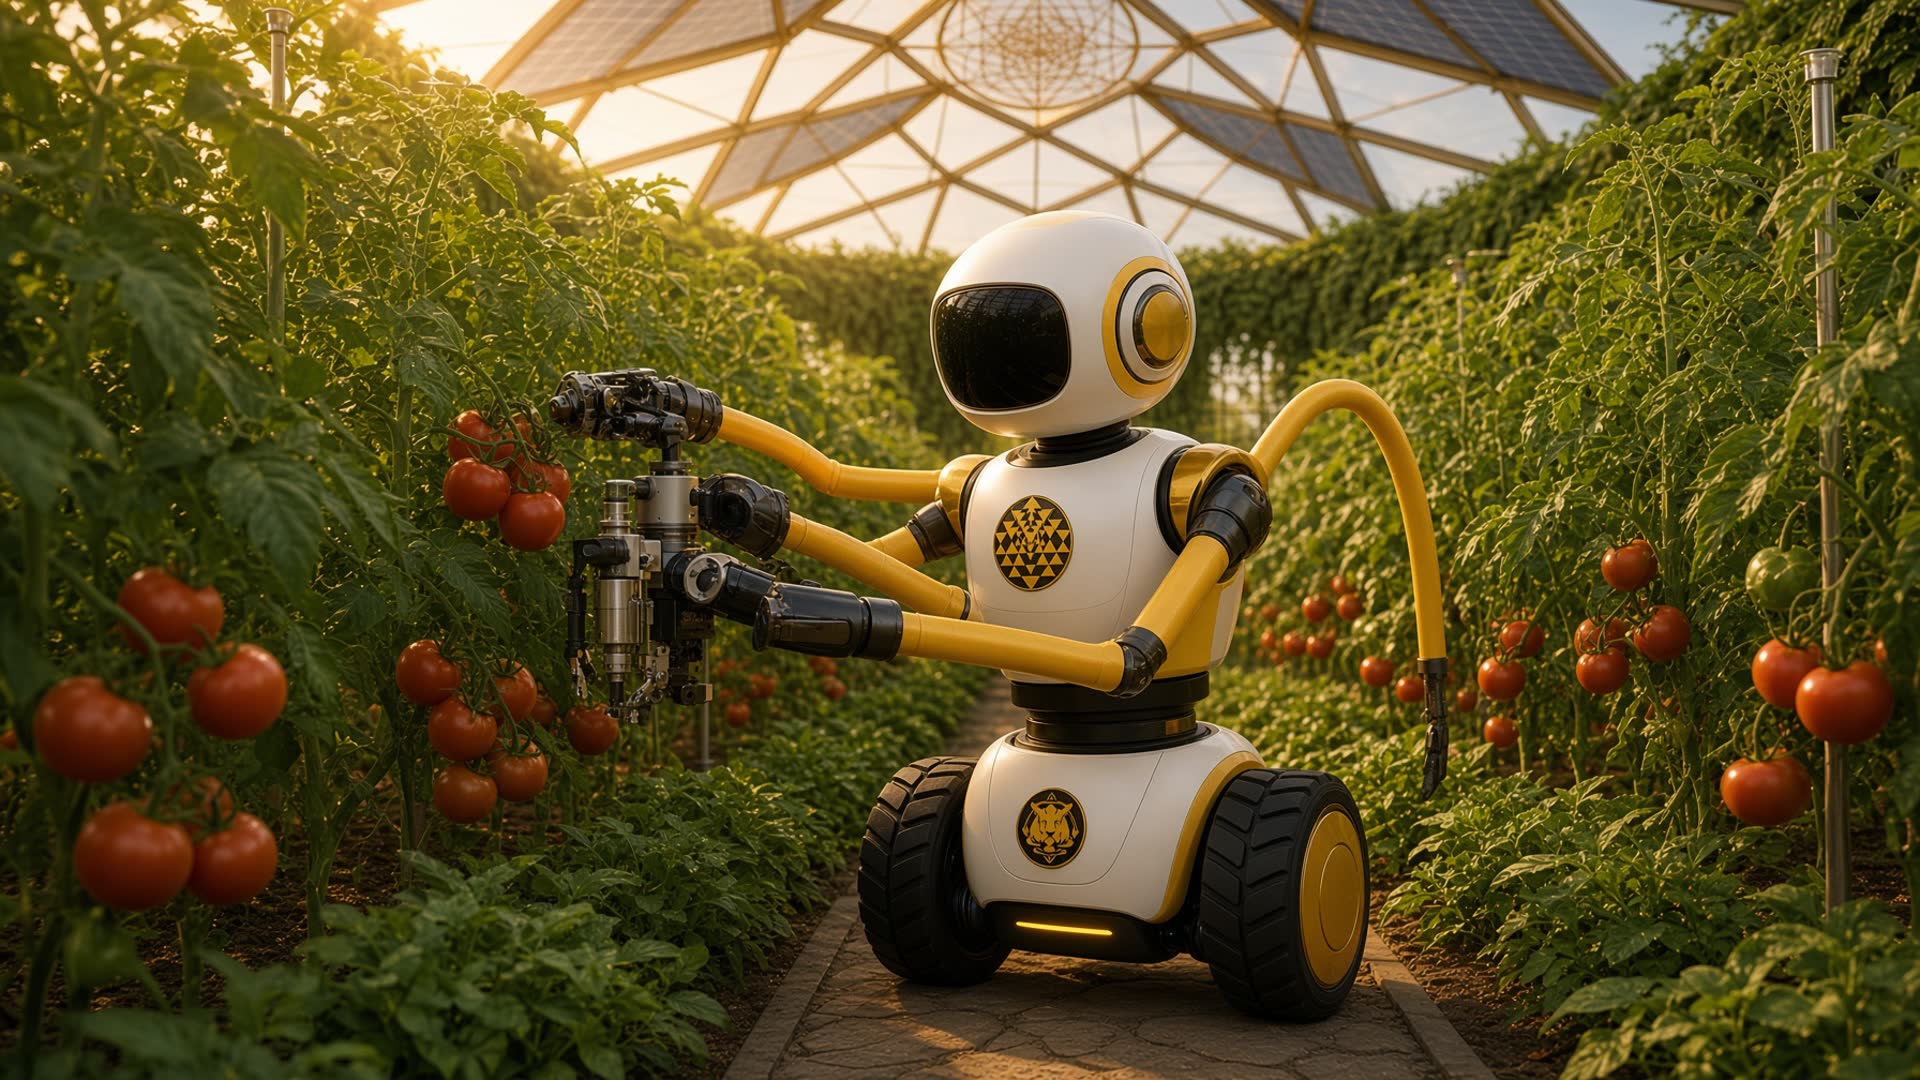
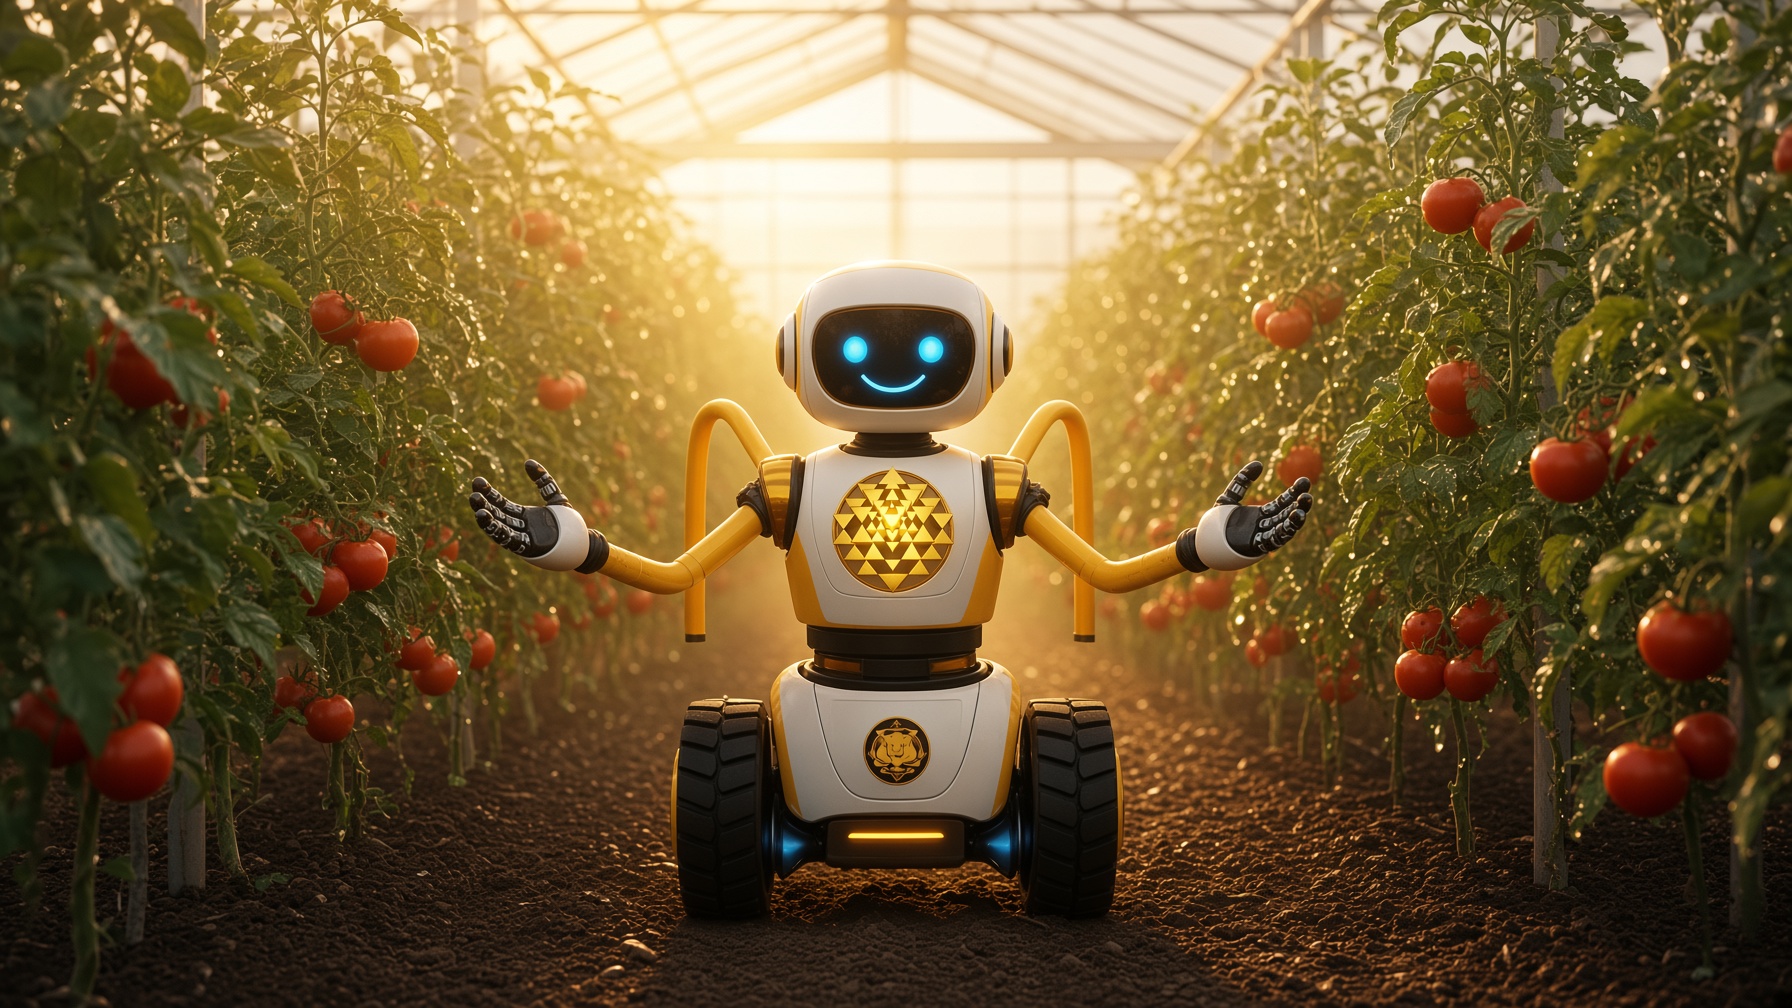
MahaaAi is designing multi-arm robotic platforms — one white-and-gold family with the Sri Yantra emblem — intended for observation, plant care, irrigation support, pruning, manipulation, harvesting and governed physical interaction. Concept renderings shown; physical validation is planned.
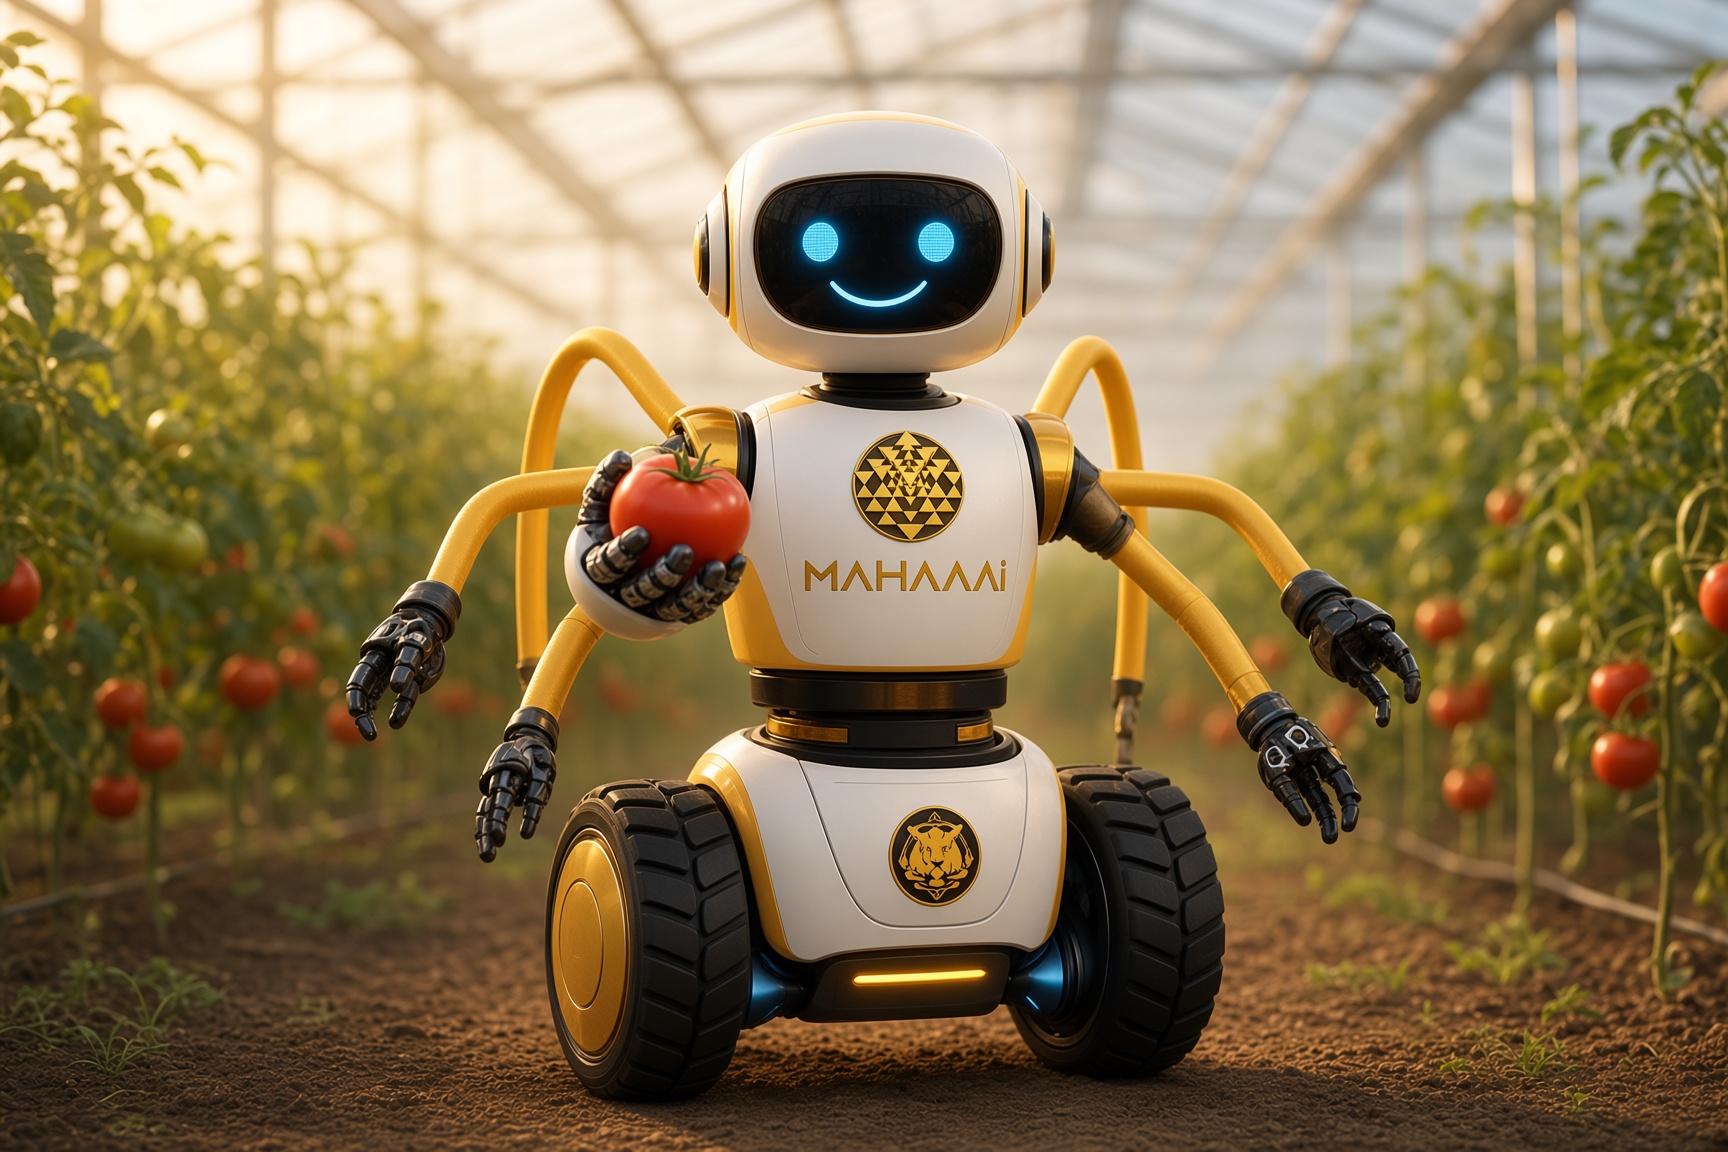 Concept rendering
MAHAA CHANDI-18™
Simulation Baseline PassedTarget architecture: 18-arm Physical AI platform for coordinated plant-scale operations.
CHANDI-18 is MahaaAi's target 18-arm Physical AI architecture for coordinated plant-scale operations. The current software-simulation baseline tests logical 18-arm arbitration, including concurrent two-arm scenarios, through a fail-closed safety boundary. Physical multi-arm validation is planned.
Platform details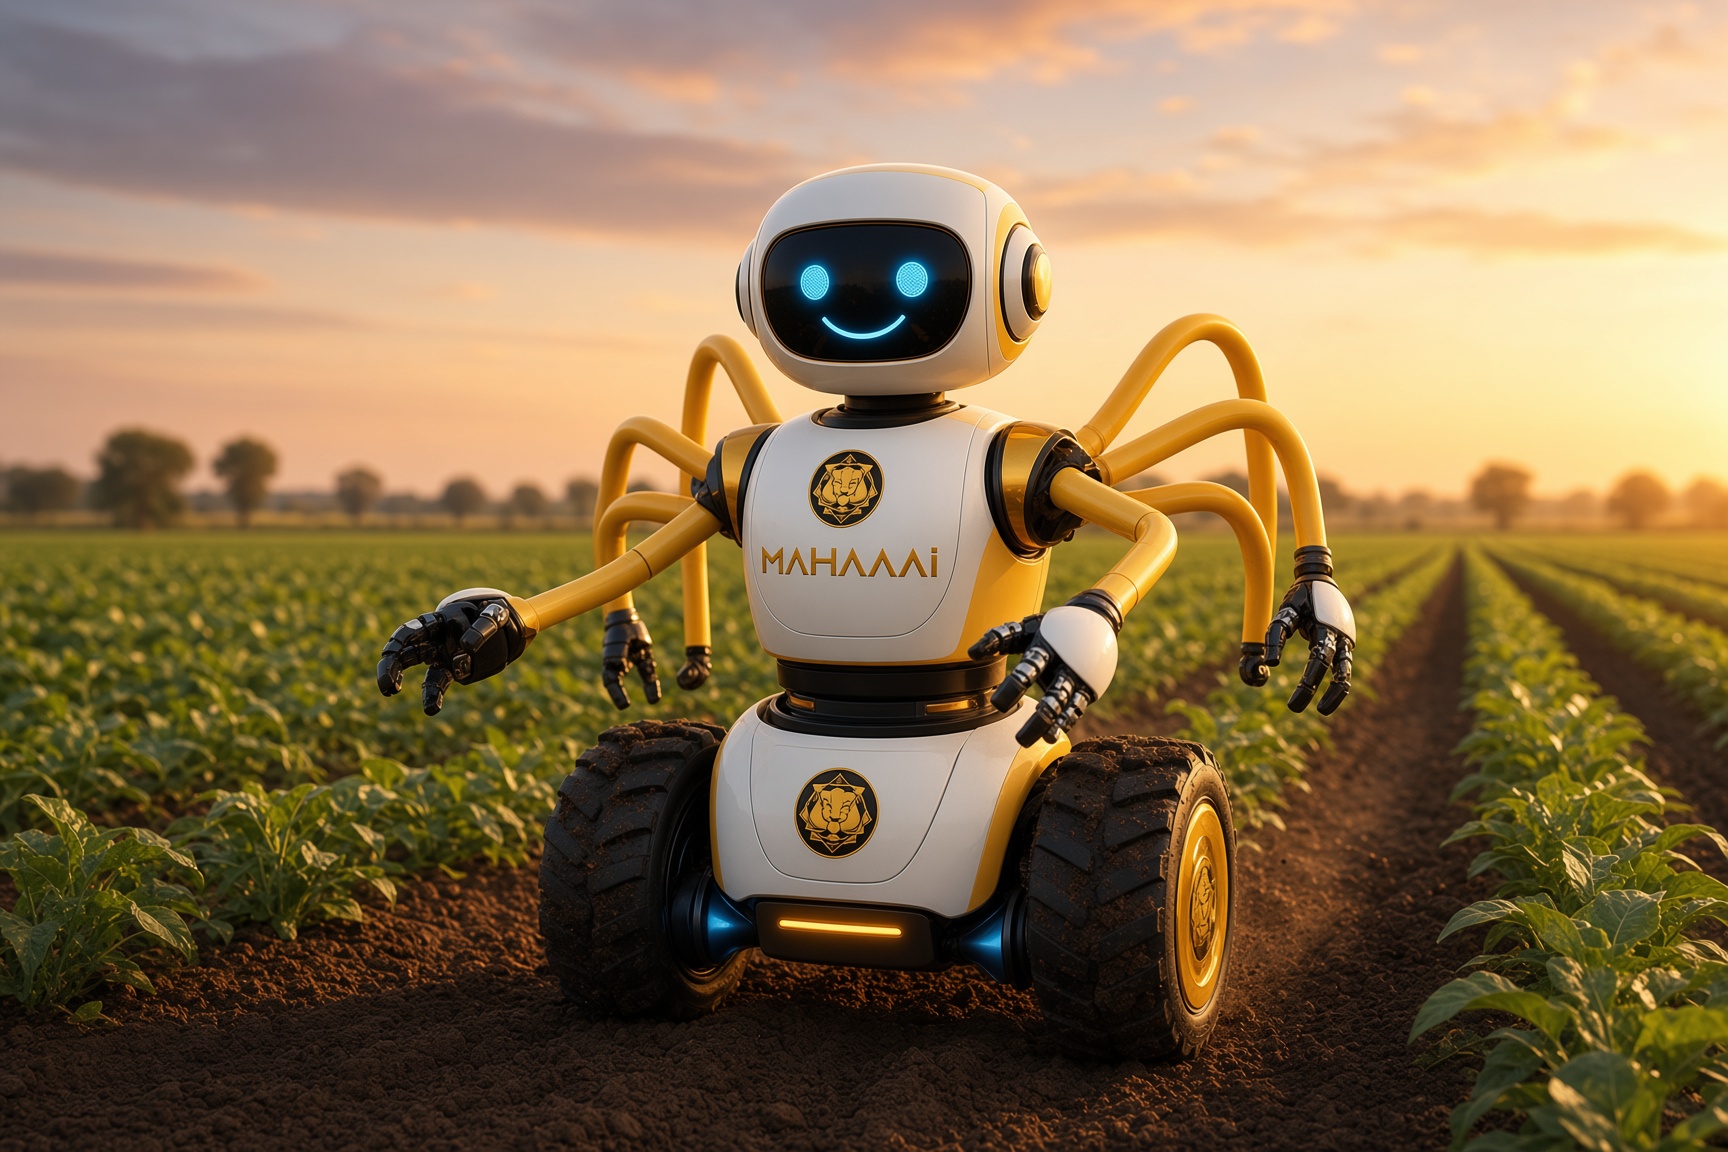 Concept rendering
MAHAA RAMA-16™
Simulation stage · physical validation plannedTarget architecture: field-oriented Physical AI platform for agricultural operations.
The field counterpart in the same MahaaAi multi-arm family: white-and-gold body, Sri Yantra emblem, weather-ready mobility, soil and irrigation sensing, and fleet-coordinated missions at the greenhouse edge. Design stage. Not presented as deployed commercial hardware.
Platform detailsNARI™ · MahaaAi Intelligence Grid™
NARI is MahaaAi’s top-level Nature-Aware Robotic Intelligence layer, connecting plant understanding, Digital Twins, reasoning, Somavati governance, robotics and traceable evidence.
Somavati is the governed safety, decision and orchestration subsystem inside NARI, providing policy checks, confidence bounds, fail-closed controls and human override.
01
Observe the physical environment through available field, robot and sensor inputs.
02
Convert observations into contextual environmental understanding.
03
Update the relevant Digital Twin representation of plant, environment, robot or mission state.
04
Evaluate context, relationships, evidence and potential actions.
05
Apply Somavati safety, policy, confidence and decision guardrails before physical action.
06
Execute approved actions through robotic and automation capabilities.
07
Capture outcomes and evidence to improve subsequent decisions under human oversight.
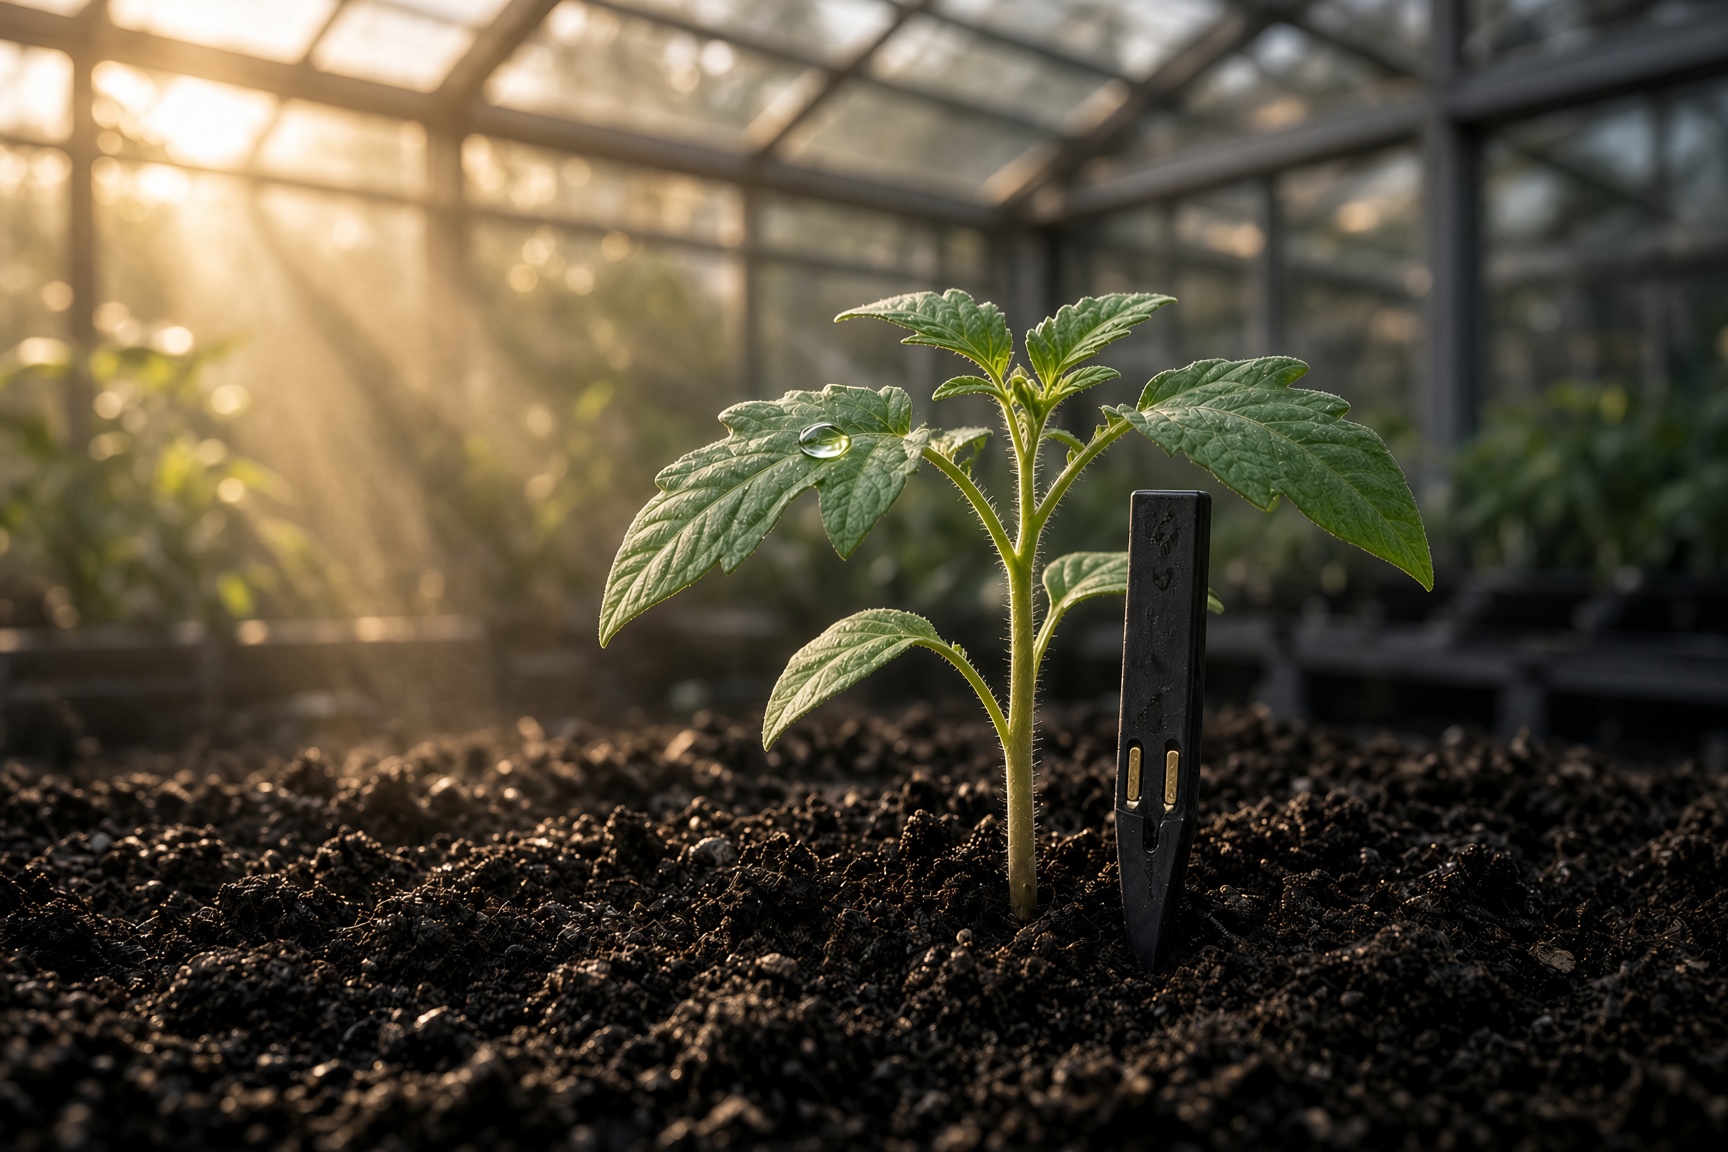 MoistureLeaf conditionGrowth stageTemperatureLightEnvironment
Plant-scale intelligence
MahaaAi combines plant signals, soil conditions, climate, vision and historical context to build continuously updated digital representations of crop condition and need. Annotations shown here are interface labels — not biological measurements from a live farm.
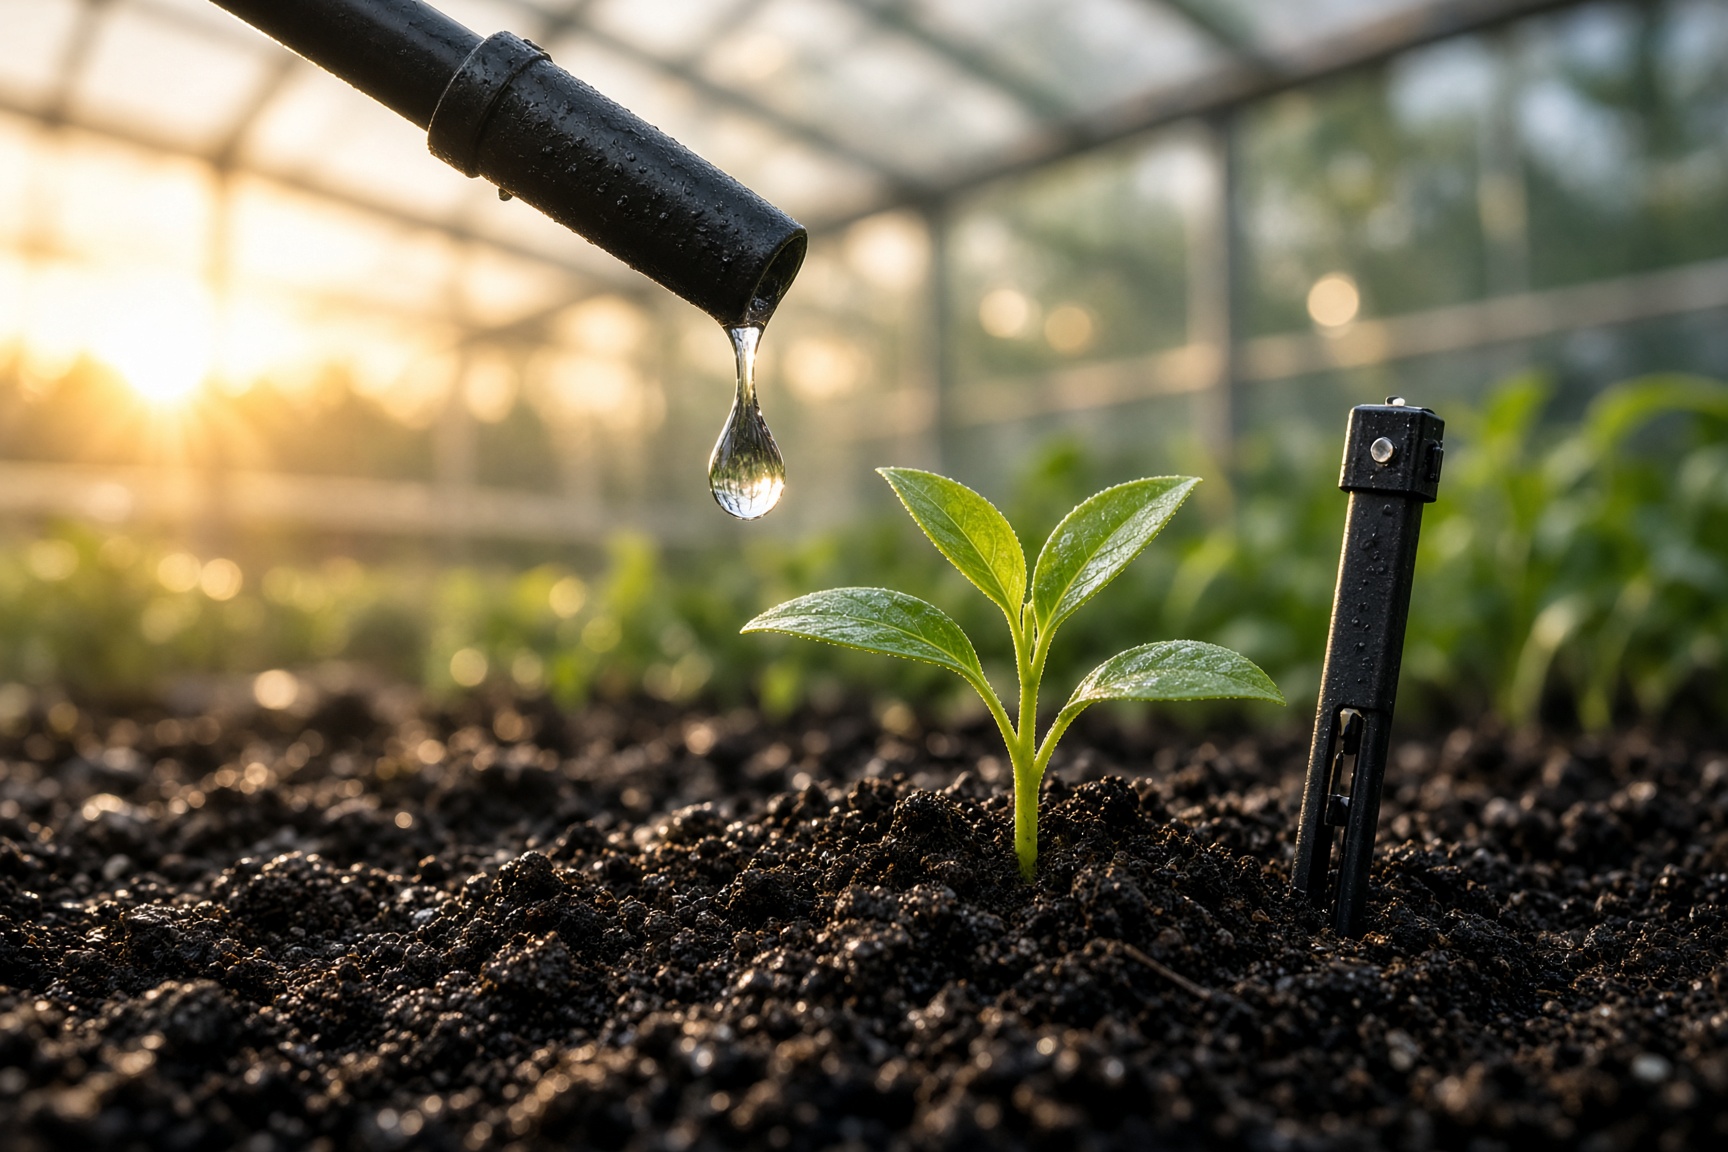
JALA — water intelligence
MahaaAi connects soil moisture, environmental conditions, plant demand and irrigation control to support more precise water allocation and outcome verification.
Explore water intelligenceRobotics Control Tower
Explore a public, read-only simulation of the NARI Intelligence Lifecycle — from sensing and Digital Twin state through Somavati governance, simulated execution and traceable evidence.
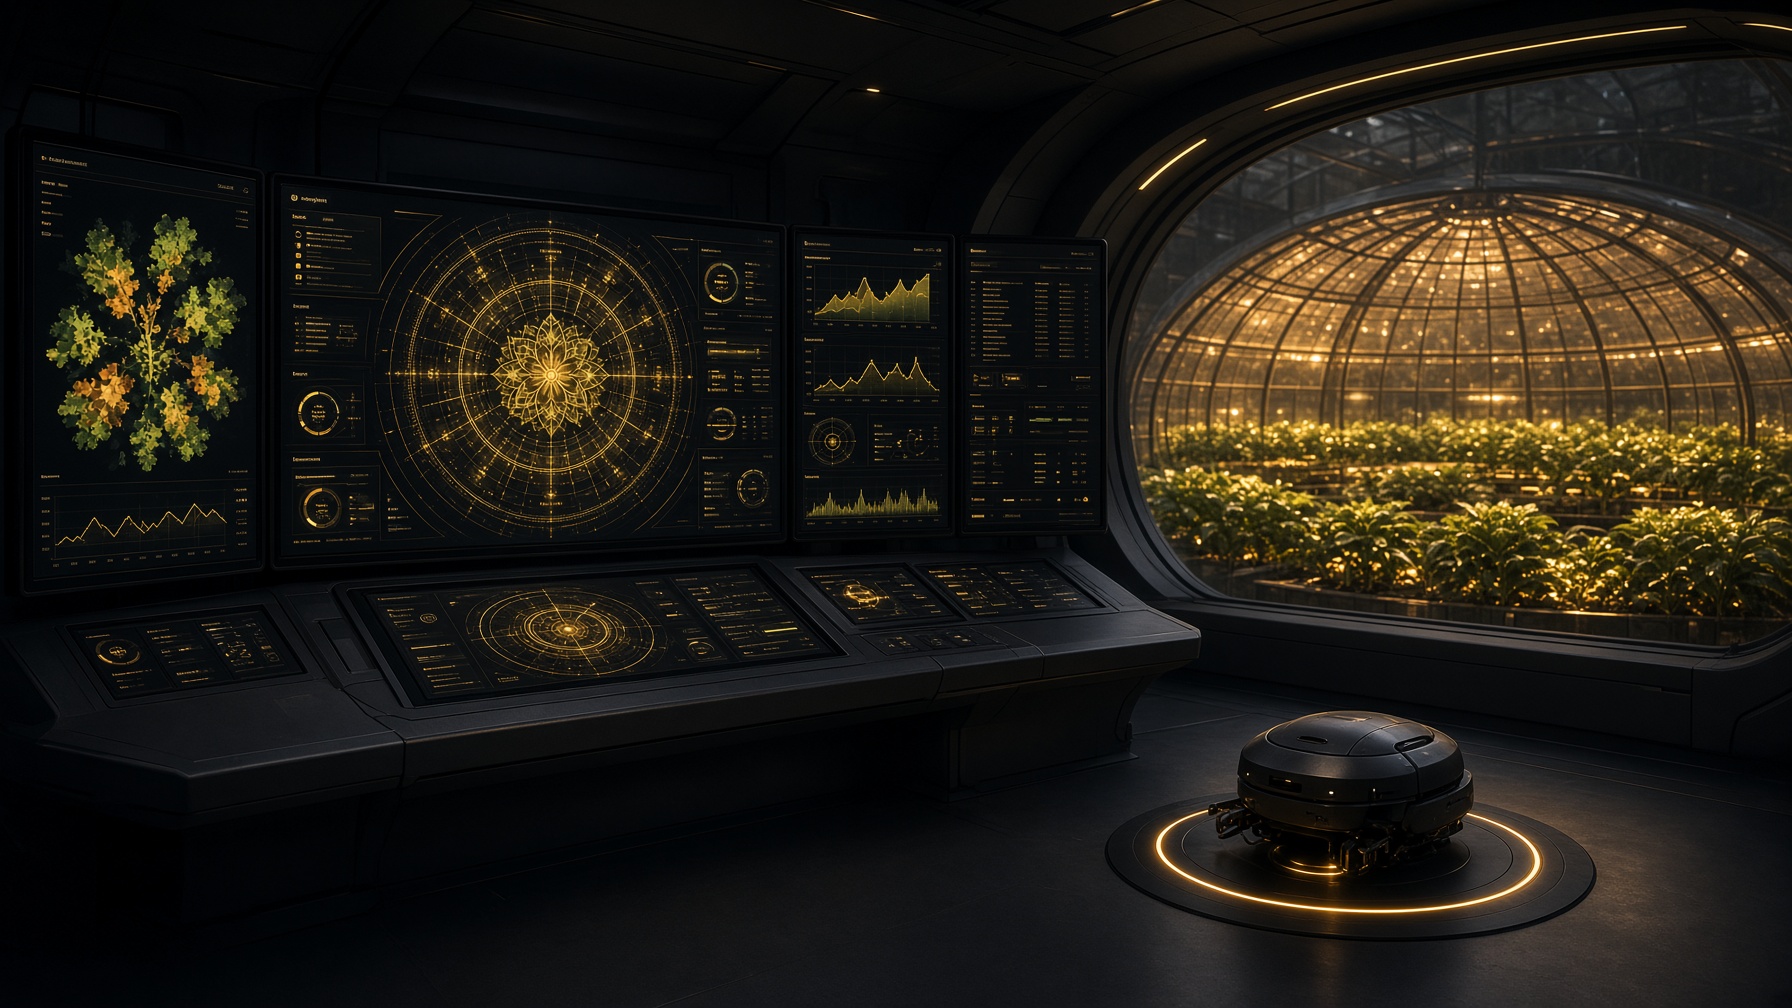
Robotics Control Tower
Synthetic simulationRobot readiness
Standby
Simulated fleet state
Mission state
Idle
No live dispatch
Plant intelligence
Mirrored
Twin in demo mode
Digital twin
Active (sim)
Illustrative
Environment
Nominal
Demo climate band
Water state
Scheduled
JALA preview
Safety review
Fail-closed
RAKSHA armed
Evidence
Logging
Trace path on
Human override
Available
Operator authority
The interactive Control Tower is a labeled synthetic demonstration of a Control Tower operational view mapped to the 7-stage NARI Intelligence Lifecycle. Demonstration telemetry is generated from synthetic simulation unless explicitly labelled as physical-test data. It is read-only and does not control physical robots. It does not expose private GitHub files, source code, credentials, physical actuator controls or live production telemetry.
NARI · Digital Twin
Inside NARI, plant twins, robot twins and greenhouse twins share one layer. Preview data is synthetic / simulation — not physical robot telemetry.
Concept renderingInteractive 3D Digital Twin · synthetic / simulation
Character intelligences
DHARA™
Fuses soil, climate, phenology and crop signals into a living representation of plant need.
DRISHTI™
Combines RGB-D, multispectral and spatial perception to observe plants, fruit, aisles and operating environments.
JALA™
Connects plant demand, soil moisture, climate and irrigation outcomes to support precision water decisions.
KSHETRA™
Transforms plant and environmental understanding into bounded operational plans across robots, tasks, energy, water and time.
RAKSHA™
Applies safety constraints, policy checks and fail-closed behavior before autonomous physical actions are authorized. Operates with Somavati governance. Current evidence is a software-level Safety Gate in simulation; no functional-safety certification is claimed.
ANKUR™
Tracks plant development and verified outcomes to improve future decisions under governed learning and human oversight.
Robotics Lab Fleet 1™
Concept renderingProtected-environment plant care, inspection and manipulation.
Concept renderingOutdoor mobility, sensing and field operations.
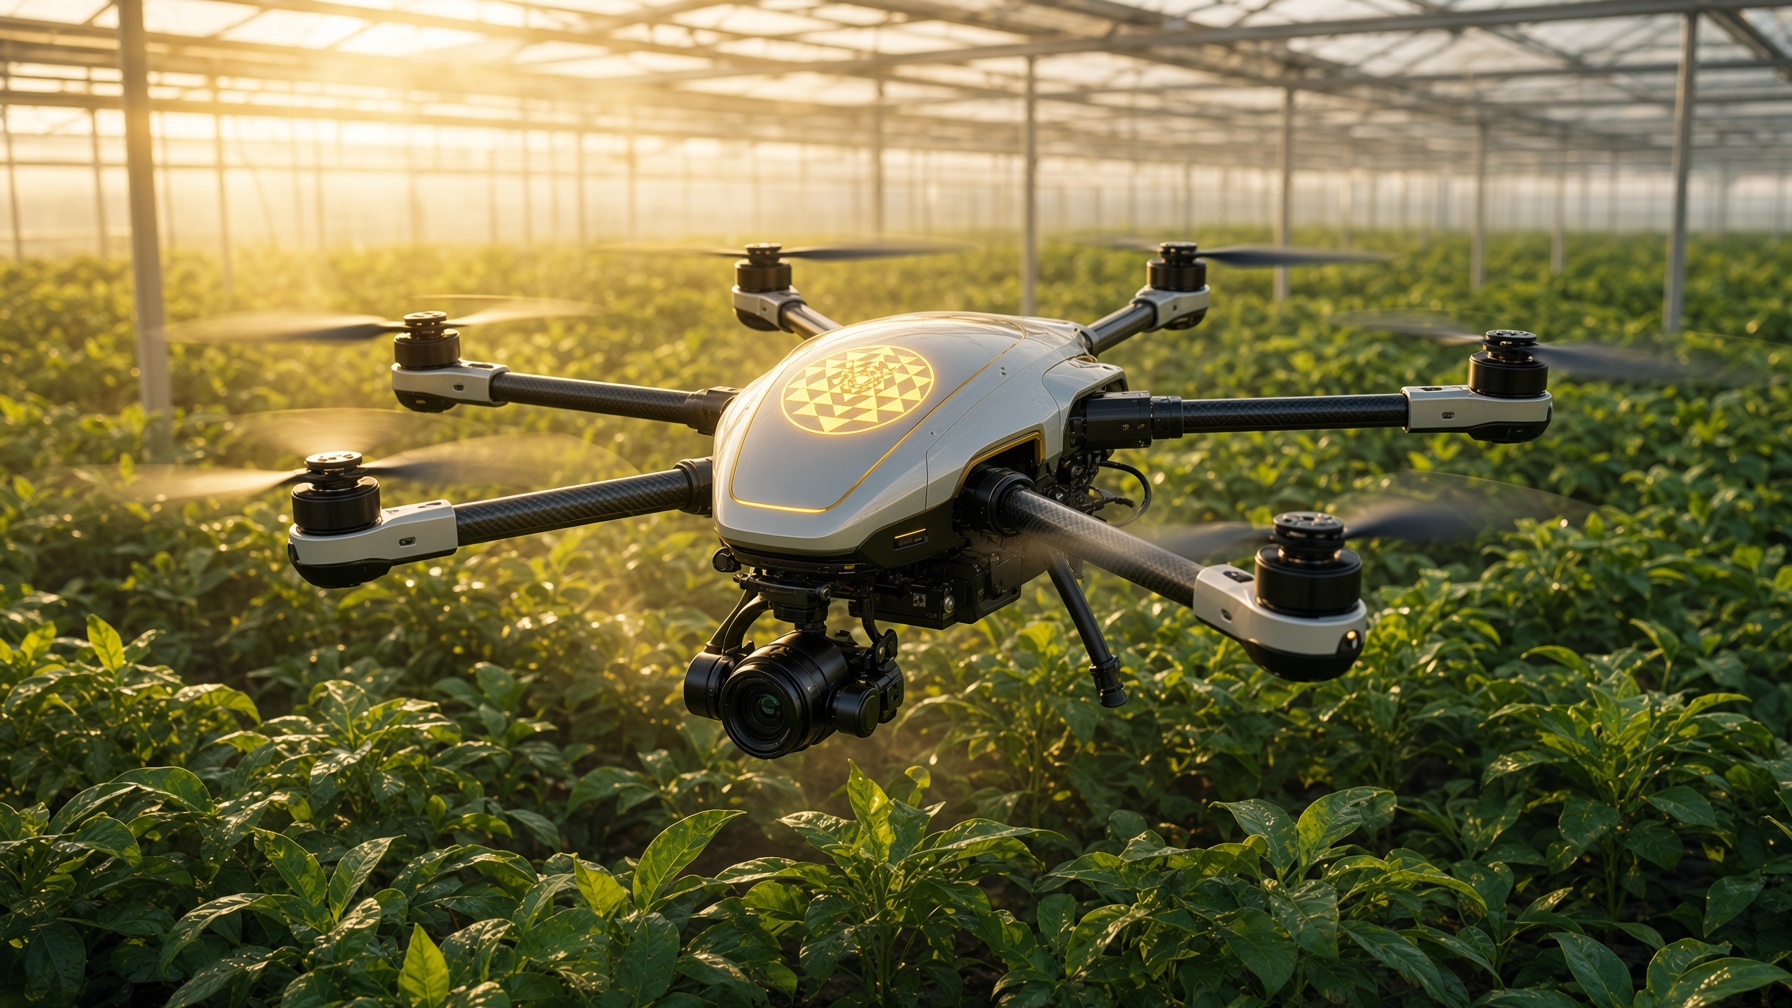 Concept rendering
Canopy observation, environmental reconnaissance and multimodal sensing.
Engineered for evidence
Deterministic software-integration baseline passed; no physical validation implied.
Virtual representations support observation, testing and decision evaluation in demonstration mode.
Decision pathways are designed to preserve explainability and audit evidence.
Autonomous actions are designed to remain bounded by explicit Somavati safety constraints and human oversight.
Learning language on this site means governed model updates from plant, environmental and verified outcome signals — not uncontrolled self-learning.
Controlled robot testing, physical evidence and field validation are planned; none has been completed.
Protected Innovation
MahaaAi is developing protected intellectual property for autonomous multi-arm robotic systems. Agriculture is the current commercialization focus. The filed platform description also covers eldercare and smart-city maintenance as broader applicability — not as current deployments.
Research → engineering → validation
 Concept rendering
Build with MahaaAi
MahaaAi works at the intersection of agriculture, robotics, AI, research and sustainable infrastructure. We welcome conversations with research institutions, agriculture operators, greenhouse partners, robotics collaborators, technology partners and strategic investors.
 Concept rendering
Plant by plant. Decision by decision. A foundation for governed, autonomous agriculture — built evidence-first.
Explore MahaaAi